OASIS
Open social simulation for studying interactions and collective behavior among up to one million agents.
GitHubMy research focuses on AI agents, reinforcement learning, and embodied intelligence.
I am currently on the job market. Please feel free to contact me.
I am a Ph.D. candidate at Dalian University of Technology and the founder of Evolving Machines Lab (EML). I was previously a visiting scholar at the University of Oxford and a research intern at the Shanghai Artificial Intelligence Laboratory.
At EML, I work on agents that continue learning from interaction and feedback. My research covers compositional generalization, on-policy learning, and open-ended multimodal tool use in digital and physical environments.
I am building three open-source ecosystems: OASIS for large-scale agent societies; SPAgent for multimodal tool use and spatial reasoning; and Future Robots for embodied agents and compositional VLA policies.
PsySafe received an ACL 2024 Outstanding Paper Award. OASIS supports one million agents and has 5,000+ GitHub stars. It has supported dozens of papers at leading AI conferences and served as a technical foundation for startup products such as MiroFish.
My Ph.D. advisor is IEEE Fellow Prof. Huchuan Lu, and I work closely with Prof. Lijun Wang and Yifan Wang. I also collaborate with Prof. Philip Torr and Zhenfei Yin at Oxford, and previously worked with Jing Shao at Shanghai AI Lab. Of course, I have also collaborated with many talented friends—from rising early-career scholars to those at the height of their careers—too numerous to list individually here.
Open social simulation for studying interactions and collective behavior among up to one million agents.
GitHub
A multimodal agent framework for perception, spatial reasoning, and tool use.
GitHub
VLA policies and benchmarks for multi-arm collaboration and compositional generalization.
GitHub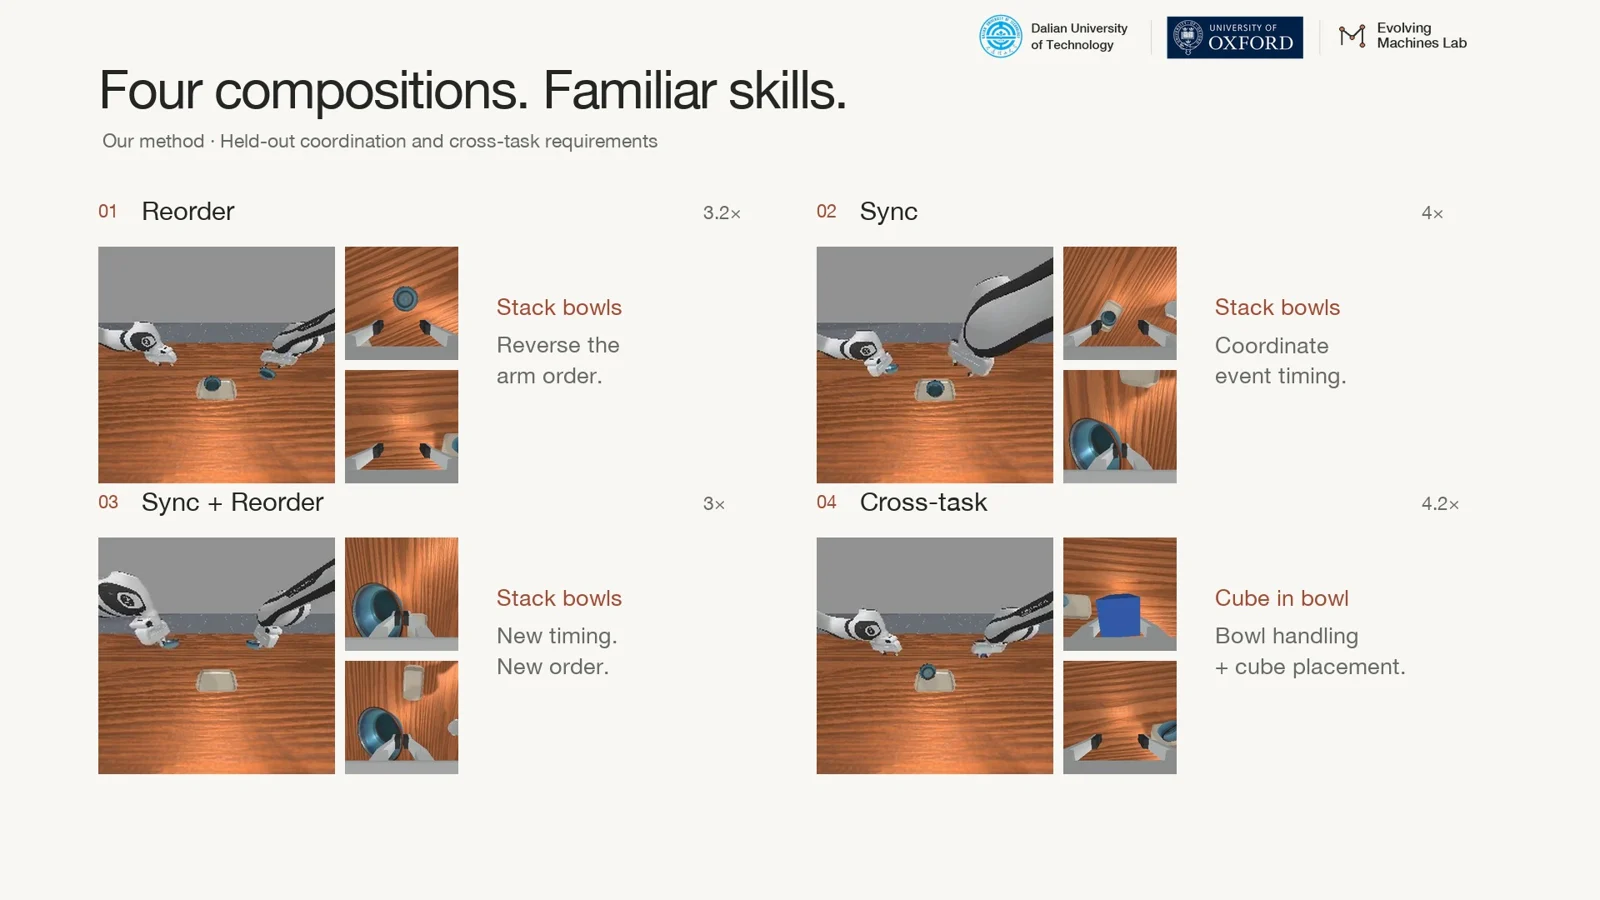
arXiv 2026
ACG-Bench tests whether dual-arm robots can reuse familiar skills under unseen orders, timing constraints, and cross-task compositions. AE-VLA combines arm-token grouping, skill-specific LoRA adapters, and arm-wise attention in a shared vision-language-action policy. It reaches 21.53% success across 17 unseen simulation conditions and 39.00% across five unseen conditions on physical SO101 robots, advancing compositional skill reuse within the Future ecosystem.

NeurIPS 2024 Workshop on Open-World Agents 2024 5000+ GitHub Stars
We propose OASIS, a generalizable and scalable social media simulator based on real-world platforms. OASIS supports large-scale simulations with up to one million users, featuring dynamic environments, diverse action spaces, and recommendation systems. We replicate various social phenomena including information spreading, group polarization, and herd effects.

Annual Meeting of the Association for Computational Linguistics (ACL) 2024 Outstanding Paper Award
We explore multi-agent system safety through the lens of agent psychology, revealing that dark psychological states constitute significant threats. We propose PsySafe, a framework focusing on identifying risky behaviors from dark personality traits, evaluating safety from psychological perspectives, and devising mitigation strategies.

arXiv 2026 200+ GitHub Stars
Think3D equips VLM agents with interactive 3D chain-of-thought reasoning by combining 3D reconstruction, ego/global-view switching, and camera-based spatial manipulation. It improves spatial reasoning in a training-free setting and reveals emergent 3D exploration strategies in RL-trained open-weight models.

European Conference on Computer Vision (ECCV) 2026
MA-VLA studies multi-arm embodied collaboration through structured atomic action assignment. Instead of treating language as a single global instruction, it decomposes cooperative behavior into mid-level atomic prompts and assigns them to individual arms, enabling explicit division of labor, role-agnostic execution via Arm Shuffle, and compositional reuse across unseen collaboration patterns in simulation and real-world evaluations.

European Conference on Computer Vision (ECCV) 2026
Attention-DP3 introduces a spatially object-aware 3D diffusion policy for manipulation in cluttered scenes. It lifts open-vocabulary 2D segmentation masks into 3D and injects geometry-aligned object cues through Tri-field Attentional Conditioning, helping the policy attend to target geometry, suppress distractors, and remain robust as scene clutter increases.

International Conference on Learning Representations (ICLR) 2026
We propose CoMAS, a framework for self-evolution of LLM-based agents through interaction rewards. Agents interact in a forum-like setting, evaluate each other, and optimize policies from self-produced reward signals, enabling continuous co-evolution without external supervision.

Transactions on Machine Learning Research (TMLR) 2026
This survey formalizes agentic reinforcement learning as the shift from single-step LLM reinforcement learning to temporally extended decision-making in dynamic environments. Synthesizing more than 500 works, it organizes the field by agent capabilities and applications while cataloging open-source environments, benchmarks, and frameworks.

Visiting Ph.D. Student
Supervisor: Prof. Philip Torr
Sep. 2025 - Mar. 2026

Ph.D. in Signal and Information Processing
Advisor: Prof. Huchuan Lu
Sep. 2022 - Present
M.S. in Mechanical Engineering
Sep. 2019 - Jun. 2022
Research Intern
Sep. 2023 - Nov. 2025